Cypher
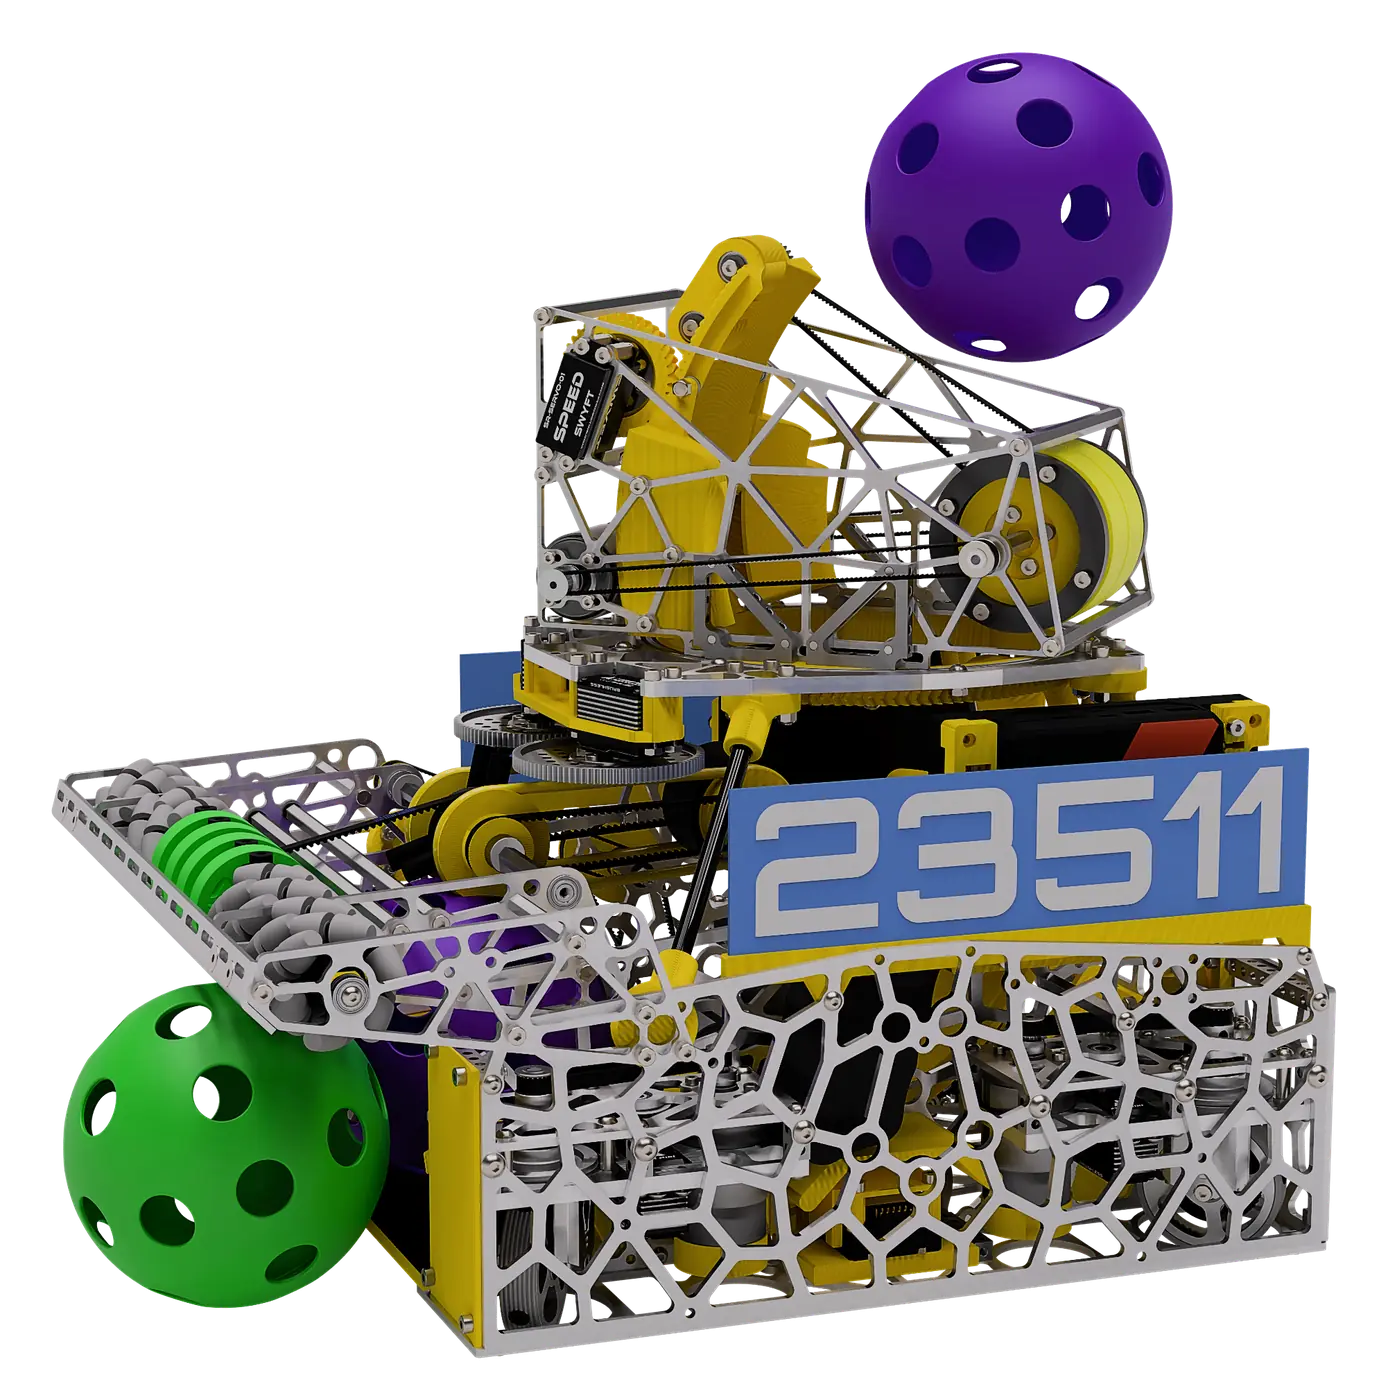
Our robot for the DECODE 2025‑26 season.
A 14 × 14.5 inch robot featuring coaxial swerve that can reliably rapid fire from anywhere on the field. It has a turret with 300 degrees of rotation, an adjustable hood, and a tilt park mechanism.
Every robot and mechanism we design is public in Onshape, free for any team to study, copy, and build on.
Other teams have used parts from our CAD 35,000+ times.
Our Open Alliance page (opens in a new tab)2025-26
Our robot for the DECODE 2025‑26 season.
A 14 × 14.5 inch robot featuring coaxial swerve that can reliably rapid fire from anywhere on the field. It has a turret with 300 degrees of rotation, an adjustable hood, and a tilt park mechanism.
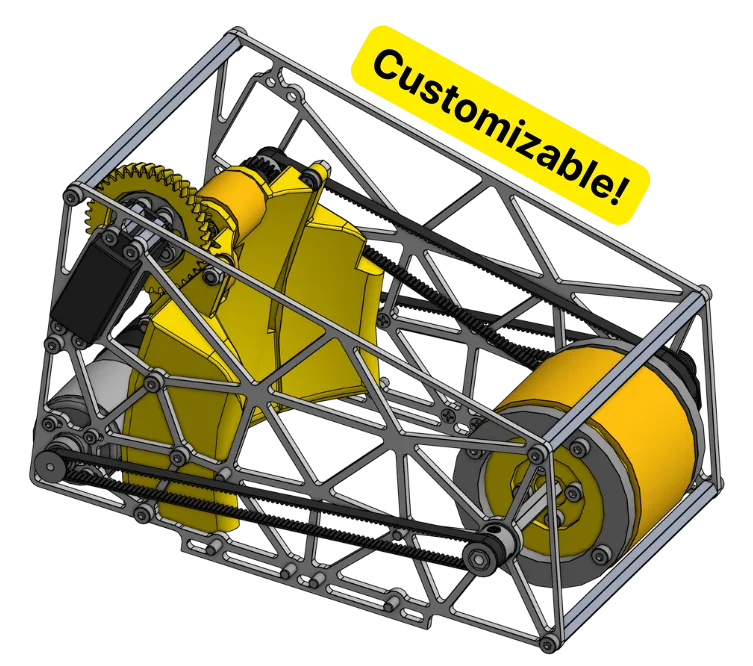
Our open-sourced shooter for the DECODE 2025‑26 season.
This customizable launcher is powered by 2 motors for the main flywheel, belted to counterrollers to eliminate backspin. An adjustable hood allows for angled shots and rapid firing.
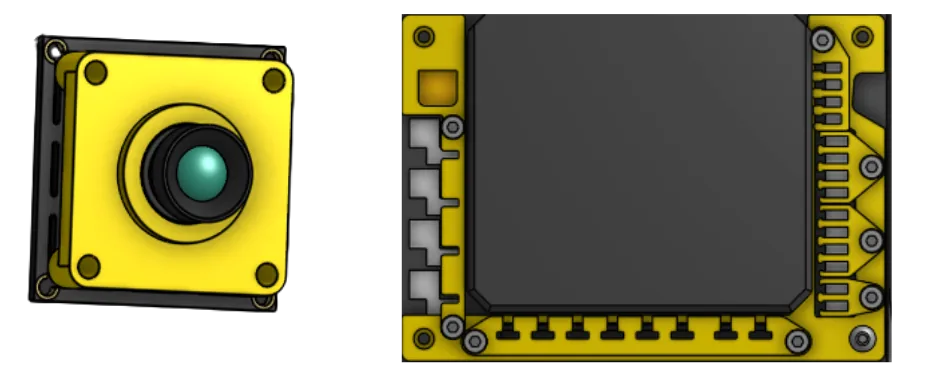
Our modular 3D-printed electronic cases help prevent wiring disconnections and protect your hubs against ESD (electrostatic discharge).
Available for a variety of devices, including Servo Hubs, Control and Expansion Hubs, Pinpoint, and cameras.
2024-25
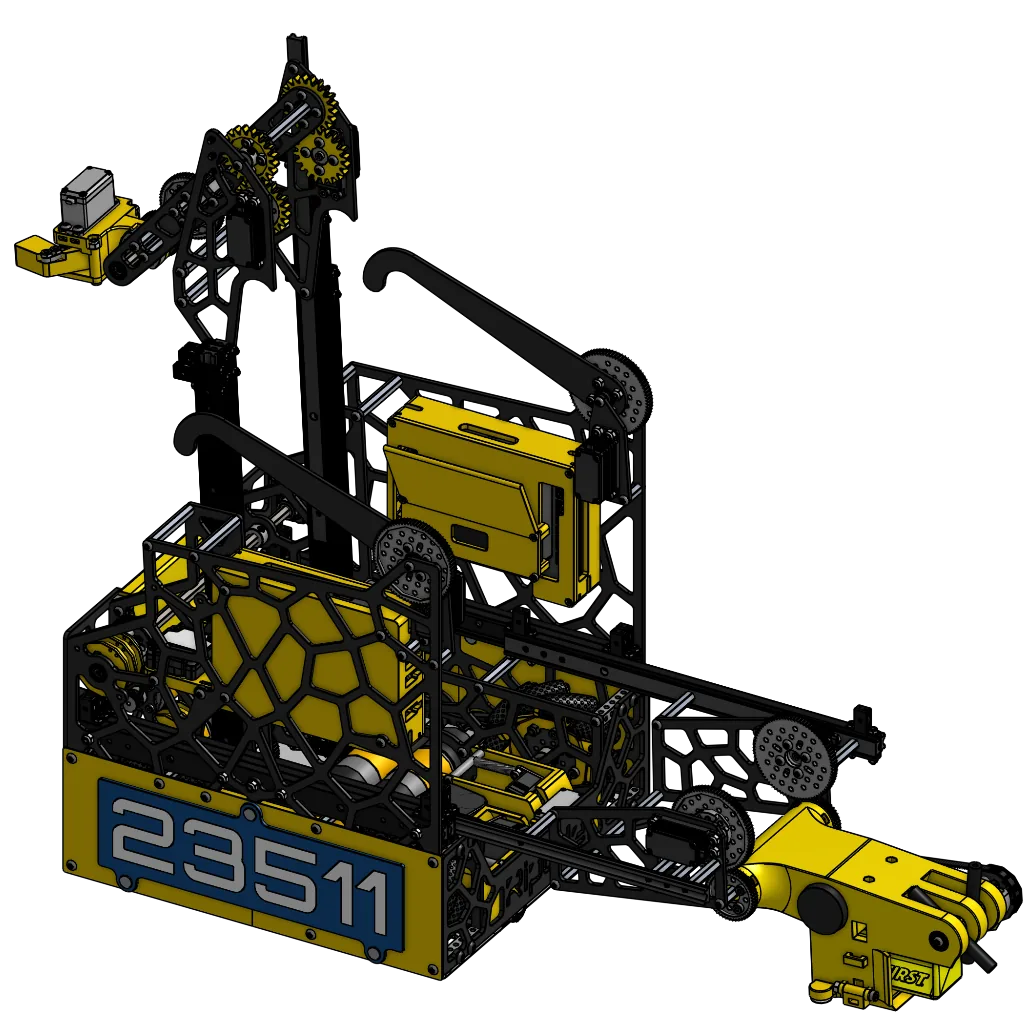
Our robot for the INTO THE DEEP 2024‑25 season.
A 12.25 × 11.5 inch robot able to complete sample or specimen cycles, with an active intake and level 3 ascent capability.
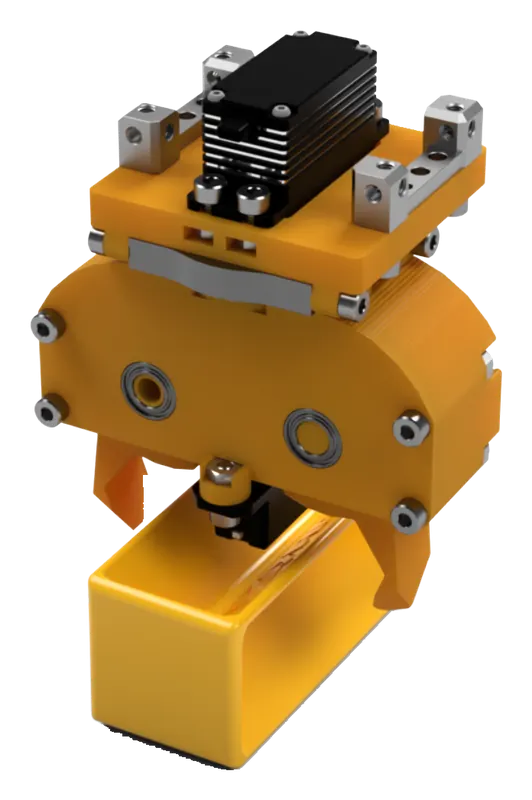
Our open-sourced claws for the INTO THE DEEP 2024‑25 season.
The intake claw can grab a sample from either the inside or the outside, and has a wrist and a color sensor for automated rejection of the wrong color.
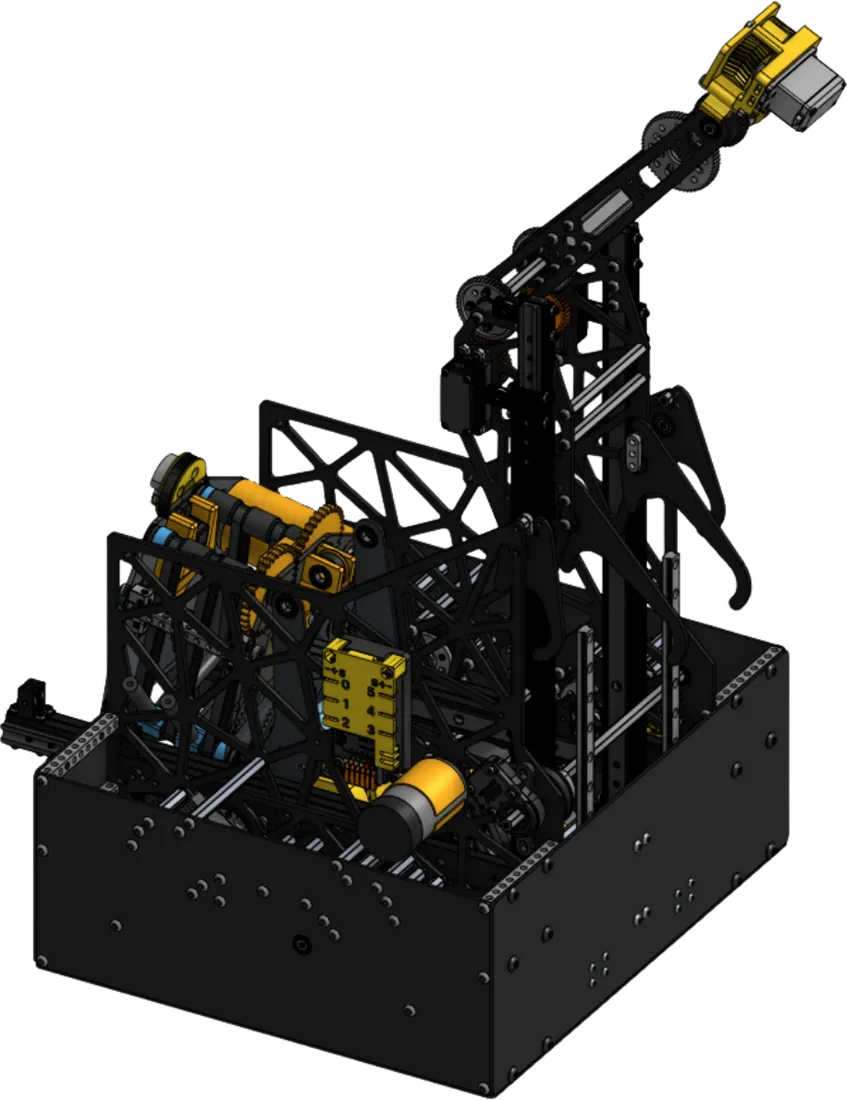
Our offseason robot heading into 2025‑26, made for INTO THE DEEP gameplay.
A 13.5 × 12 inch robot on an Octocanum (butterfly) drivetrain, with carbon fiber plates to save weight. A PTO for level 3 ascent shares the same servos as the Octocanum pods.